Master thesis topics
To have more information on any of the proposals, please contact either Prof. Ville Kyrki or one of the advisors indicated in the proposal of interest.
At present, the following master thesis proposals are available in the group:
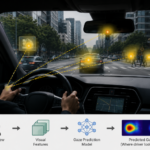
Master Thesis on “Human-Gaze-Guided Knowledge Distillation for Autonomous Driving”
Predicting human gaze—especially in egocentric or driving scenarios—is fundamentally about modeling where people will attend next, not just where they are looking now. This thesis focus on designing and implementing a pipeline that integrates feature forecasting with a gaze prediction module, conduct experiments on egocentric datasets, and systematically evaluate the benefits of future-aware representations.
Master Thesis on “Visual segmentation of elevator components with robotic platform”
This thesis focuses on developing and evaluating visual segmentation methods for elevator components using a mobile robotic platform.
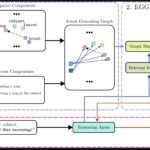
Master’s Thesis on “Tracking of Environmental Changes Using 3D Scene Graphs”
Scene understanding is crucial to advance autonomous robotic systems deployment in the real world. The selected student will focus on developing a framework for constructing 3DSGs capable of recording changes in dynamic environments as they occur.
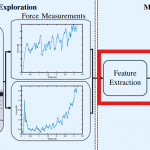
Master’s thesis Topic on Analysis of Tactile Signals
We are currently seeking for a motivated and talented master’s student to work on discriminative filtering and feature extraction for classification of tactile signals.